Build log
The build
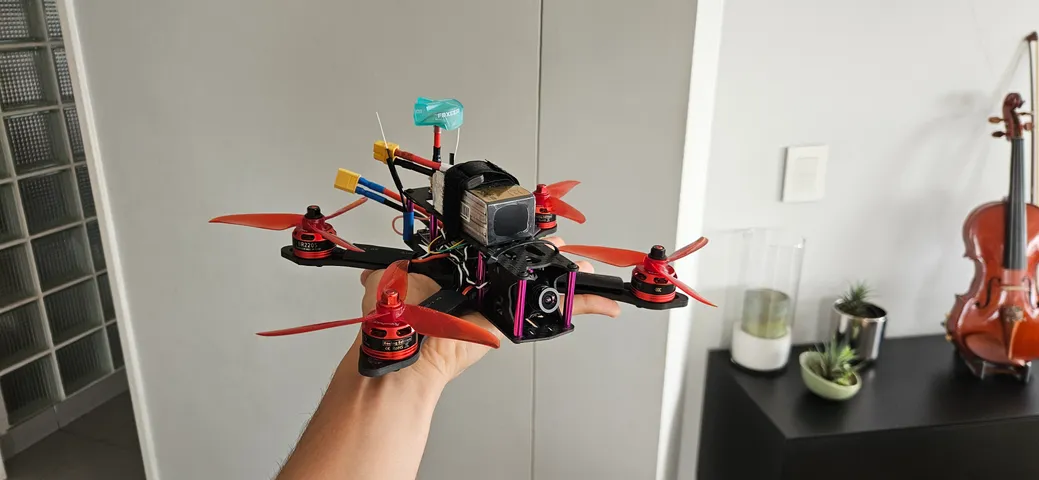
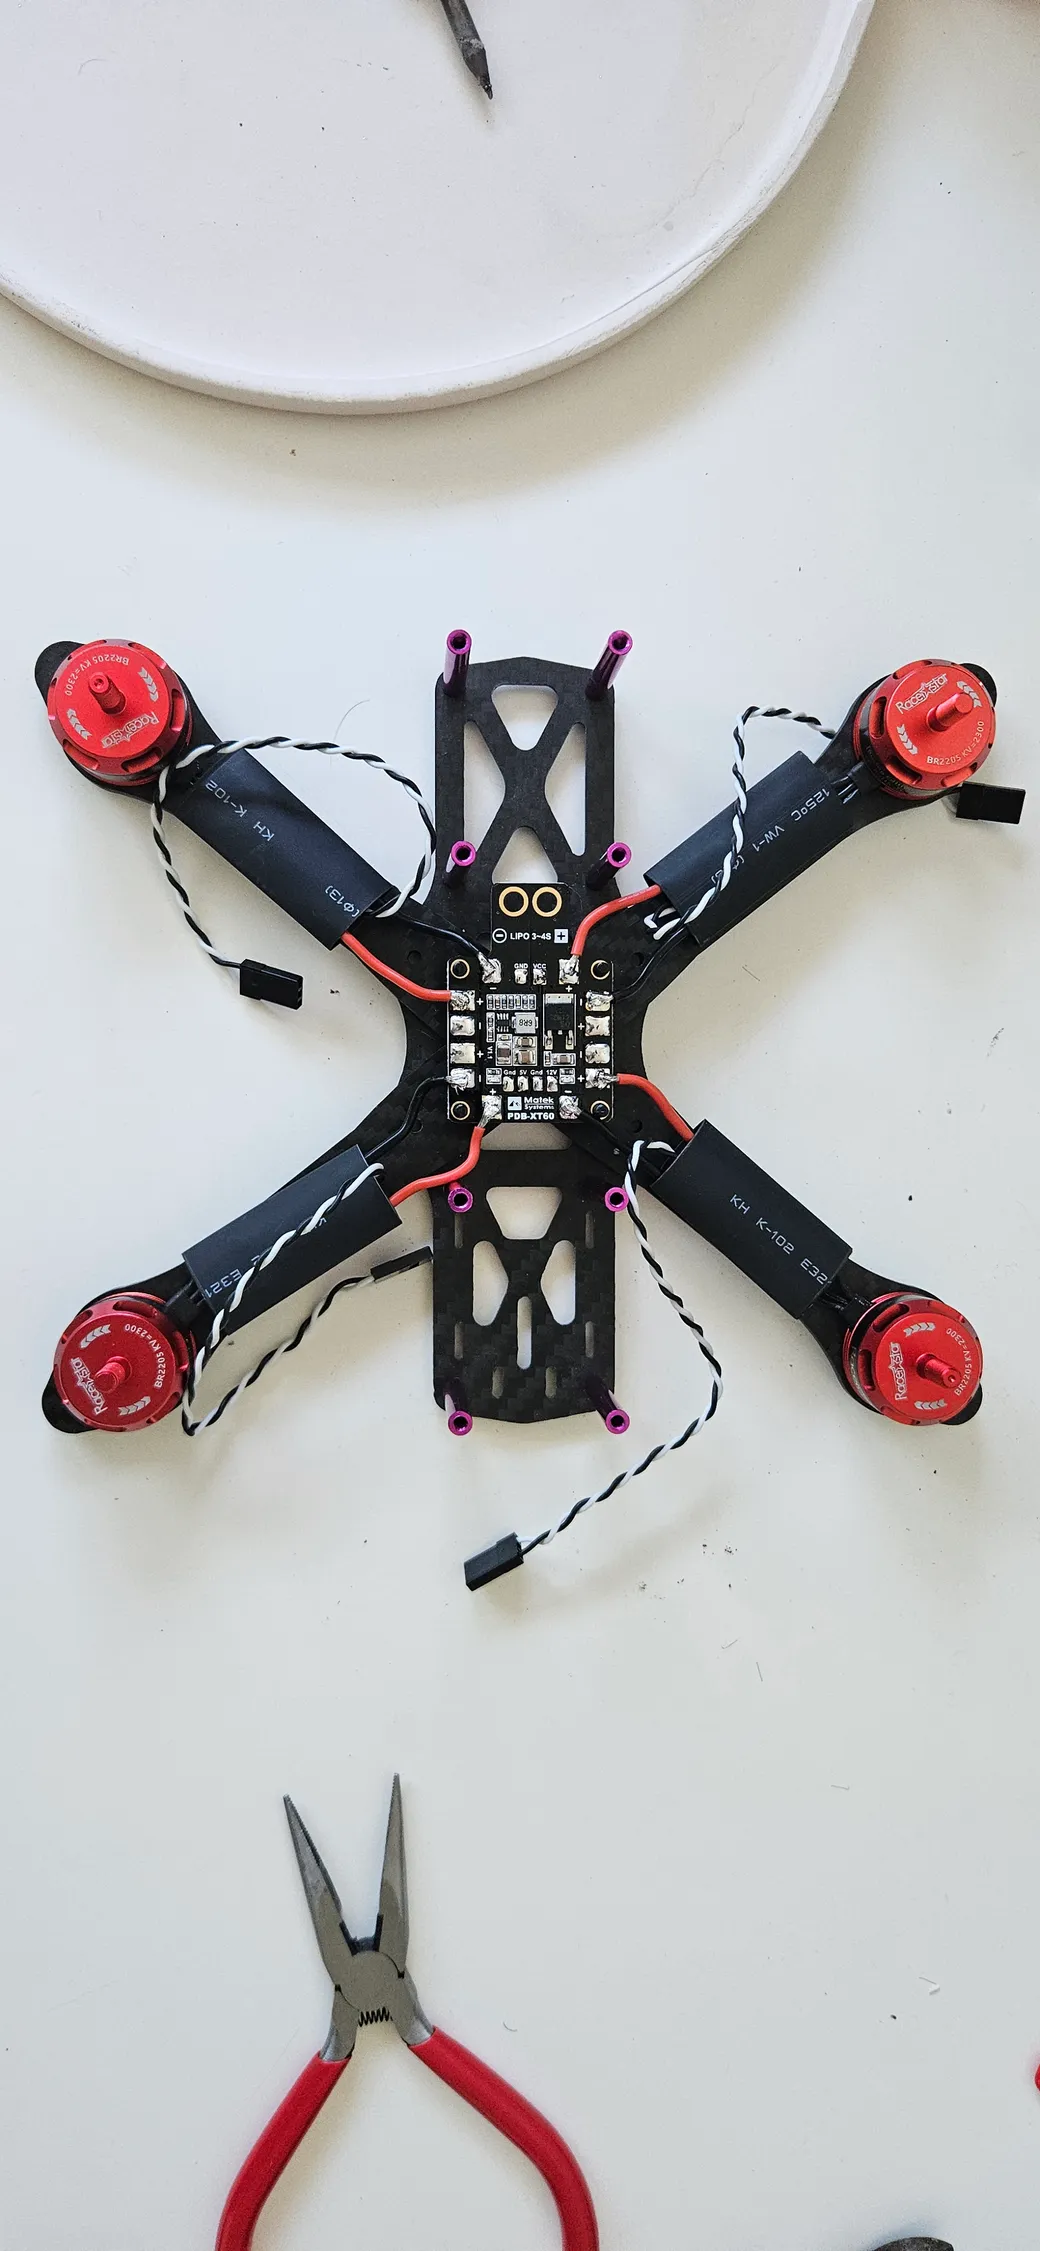
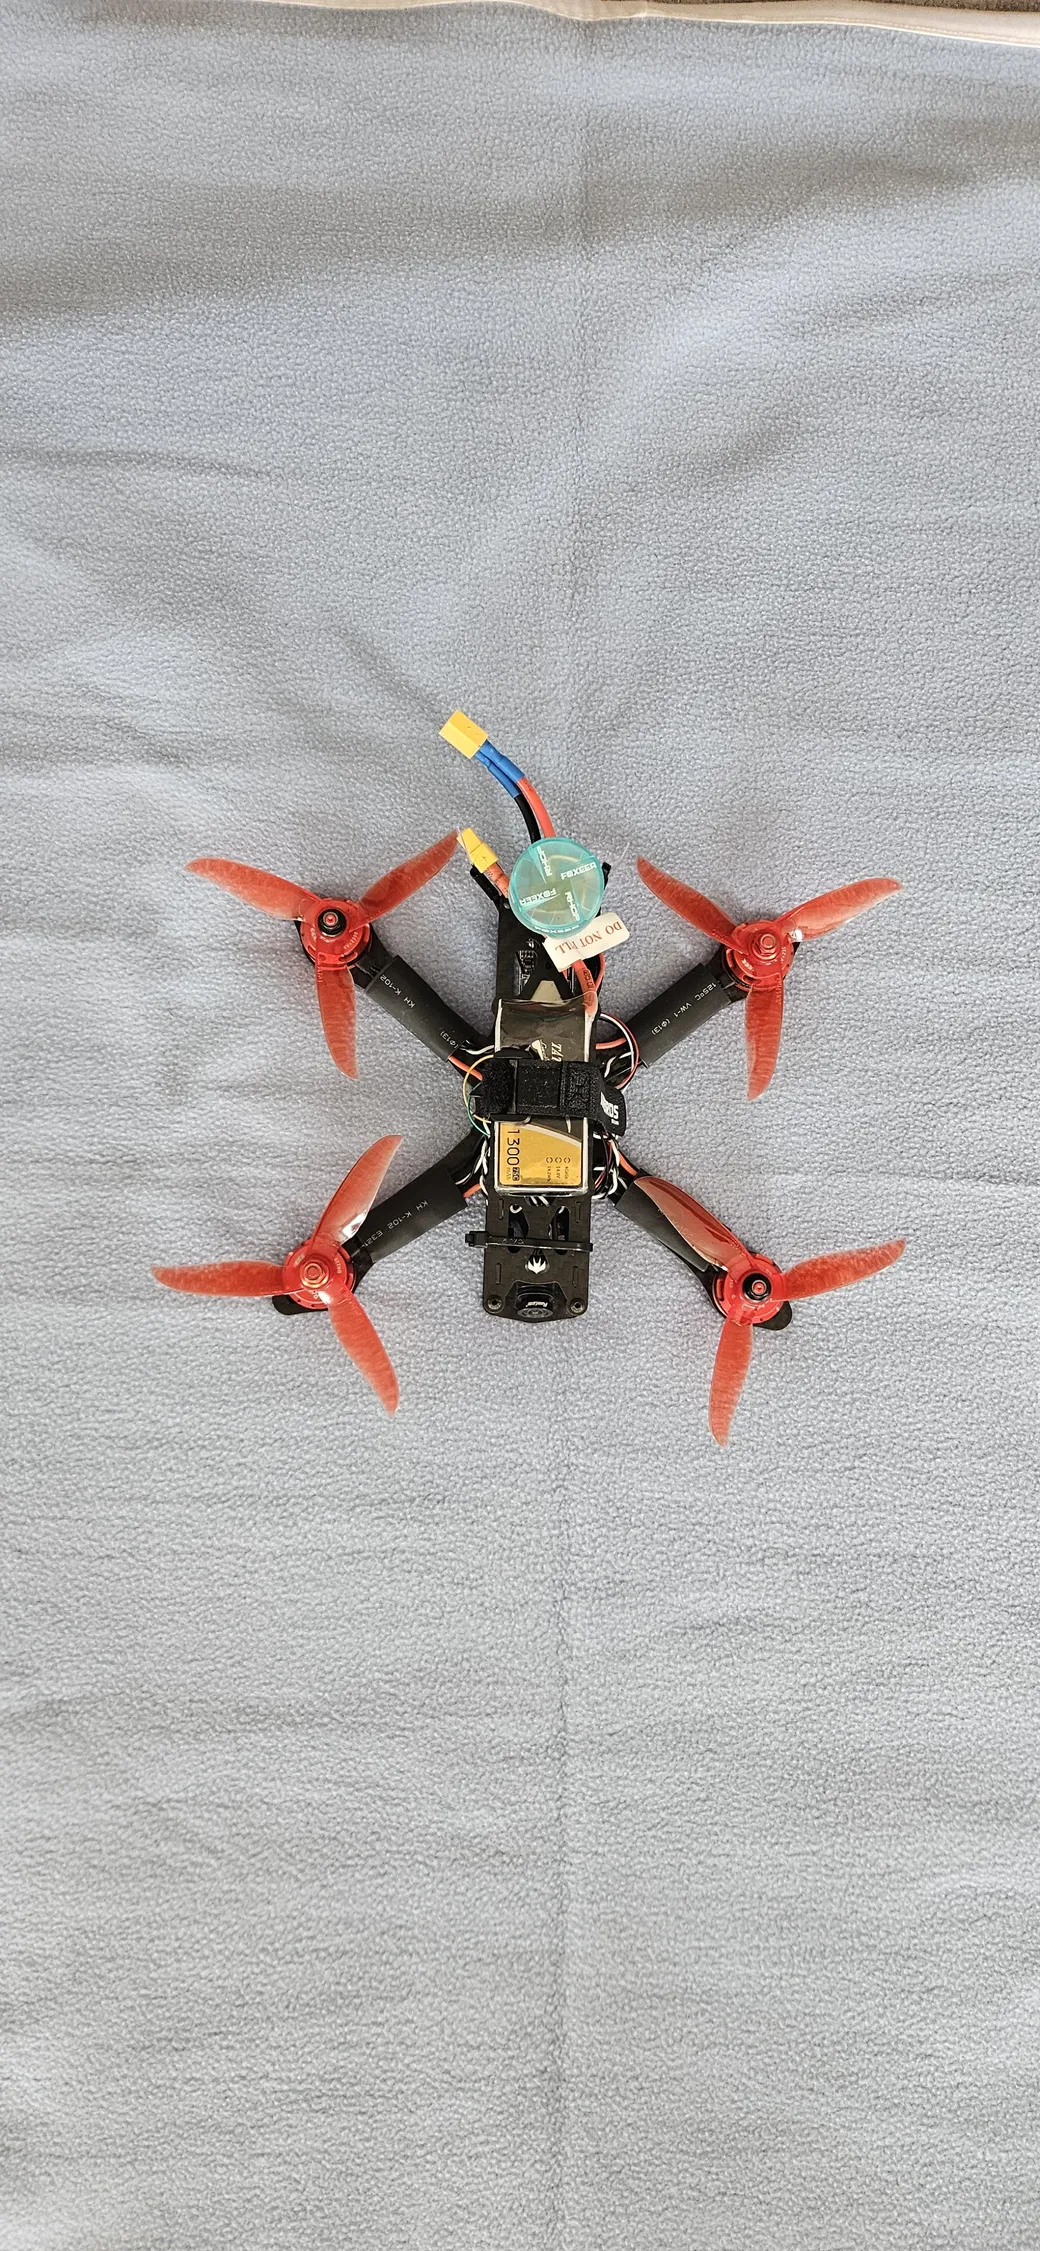
It was a set of components bought separately and not necessarily meant to work together. I based the process on youtube tutorials and pdb and flight controller manuals. Most of the time was spent soldering everything to the pdb, from esc’s (also soldered to the motors), to radio and video trasmitters.
Flying and upgrading
Flying it was almost as hard (if not harder) than building it. The unstabilized nature of fpv droning (acro mode) calls for incredible precision when moving the controller’s sticks. One has also to get used to flying it from the point of view of the camera through the visor. Initially an analog video system was used, but as I started flying it and getting into the fpv world, I realized a digital system would take the experience to a whole other level. Therefore, I bought and installed a walksnail Avatar HD system.
What I’d change next time
It was a beautiful way to get familiarized with drones, their components and the complexity of flying them without stabilization. Next time I would probably try to incorporate threadlocking to the motor and frame screws so that they are more resistant to the vibrations, as well as soft mounting the flight controller to isolate it’s IMU from vibration noise.
Video & photos