Build log
First iteration - the fight algorithm
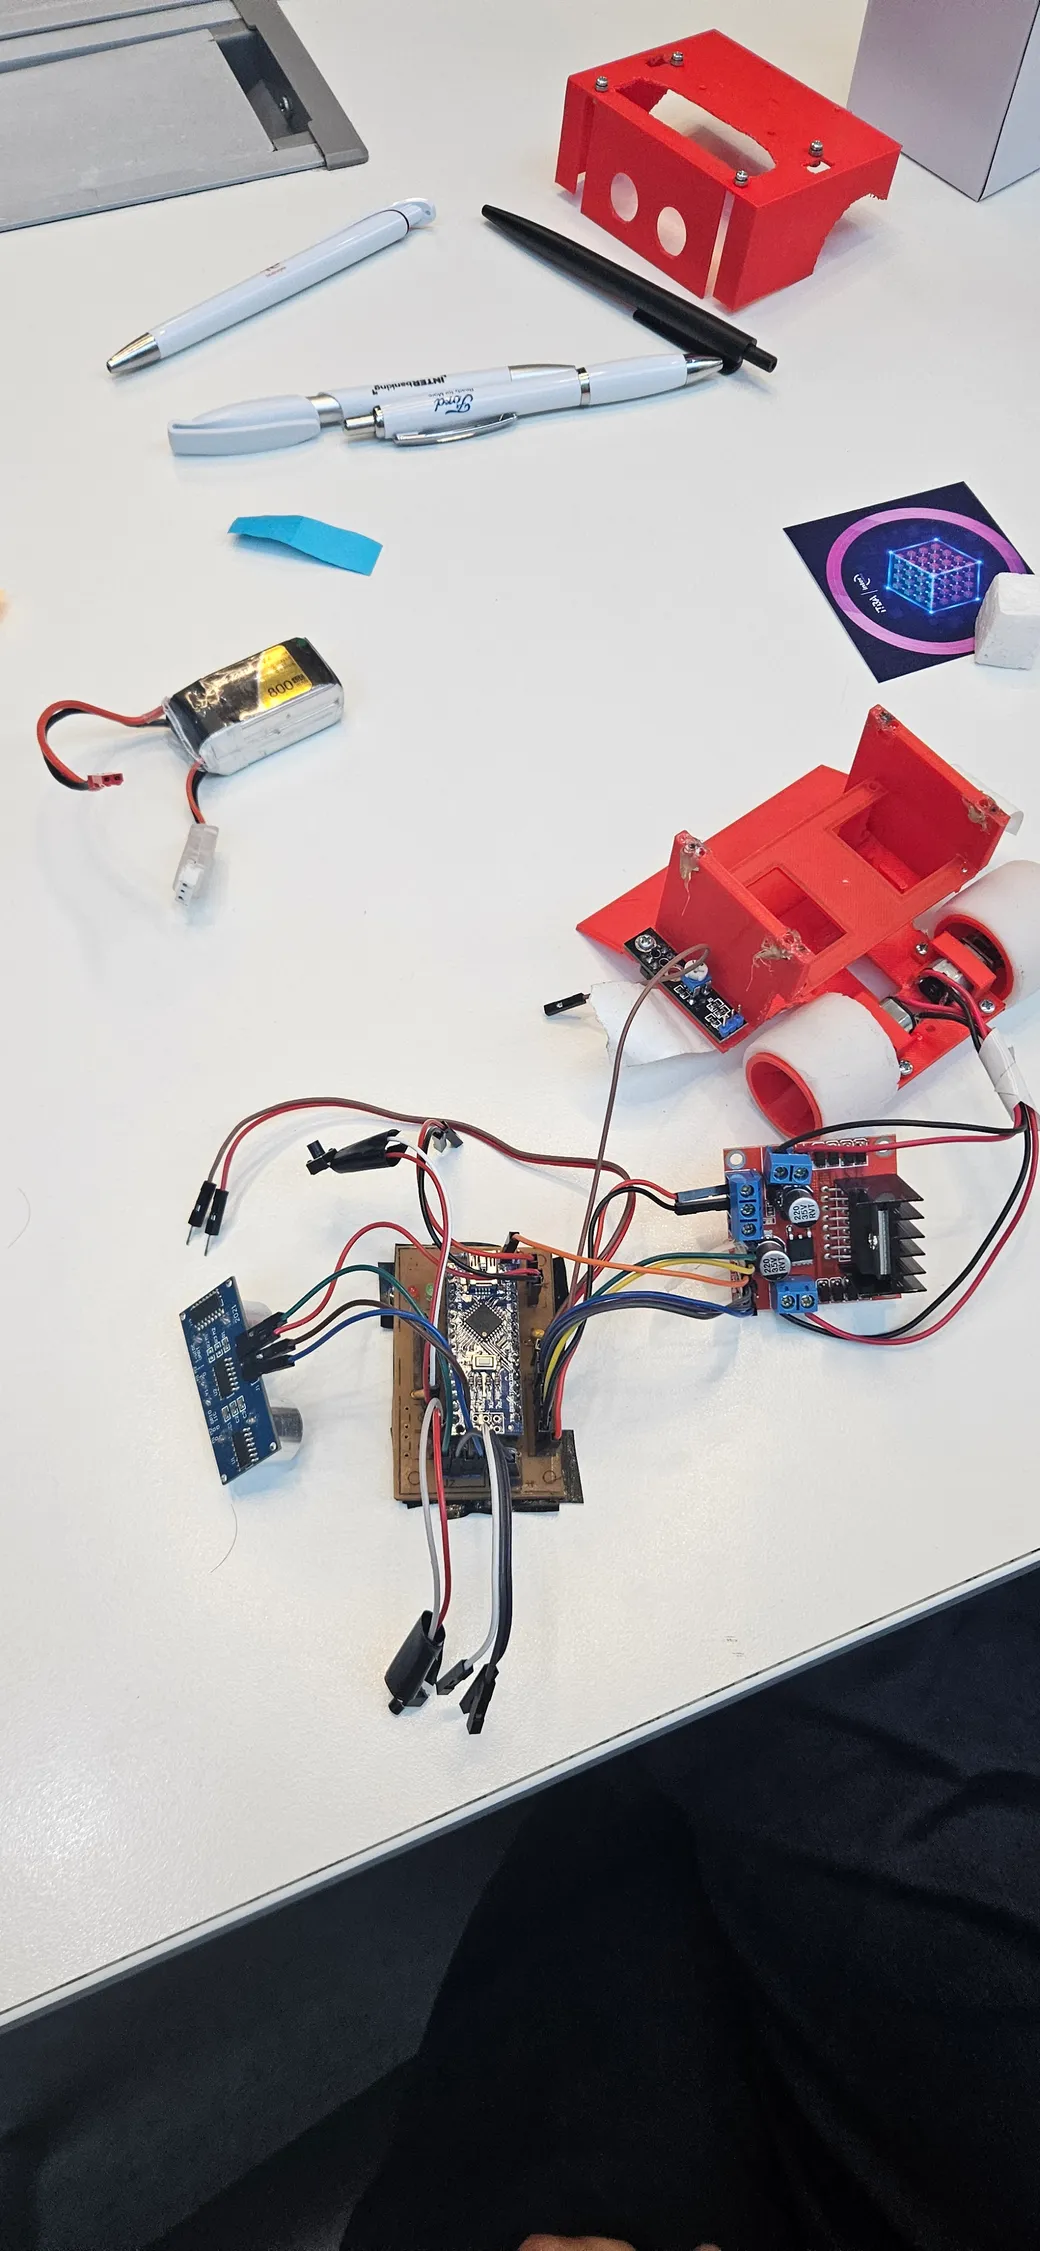
My main contribution: the search-and-attack state machine, how the IR border sensors interrupt an attack, and how aggression was balanced against falling out of the ring. The focus was put on making the events non-blocking so that the sensor checks were as fast as possible and imminent situations could be handles in real time, such as being at the border of the dohyō (registered by an infrared sensor) and needing urgent action to avoid falling.
Second iteration - memory and better hardware
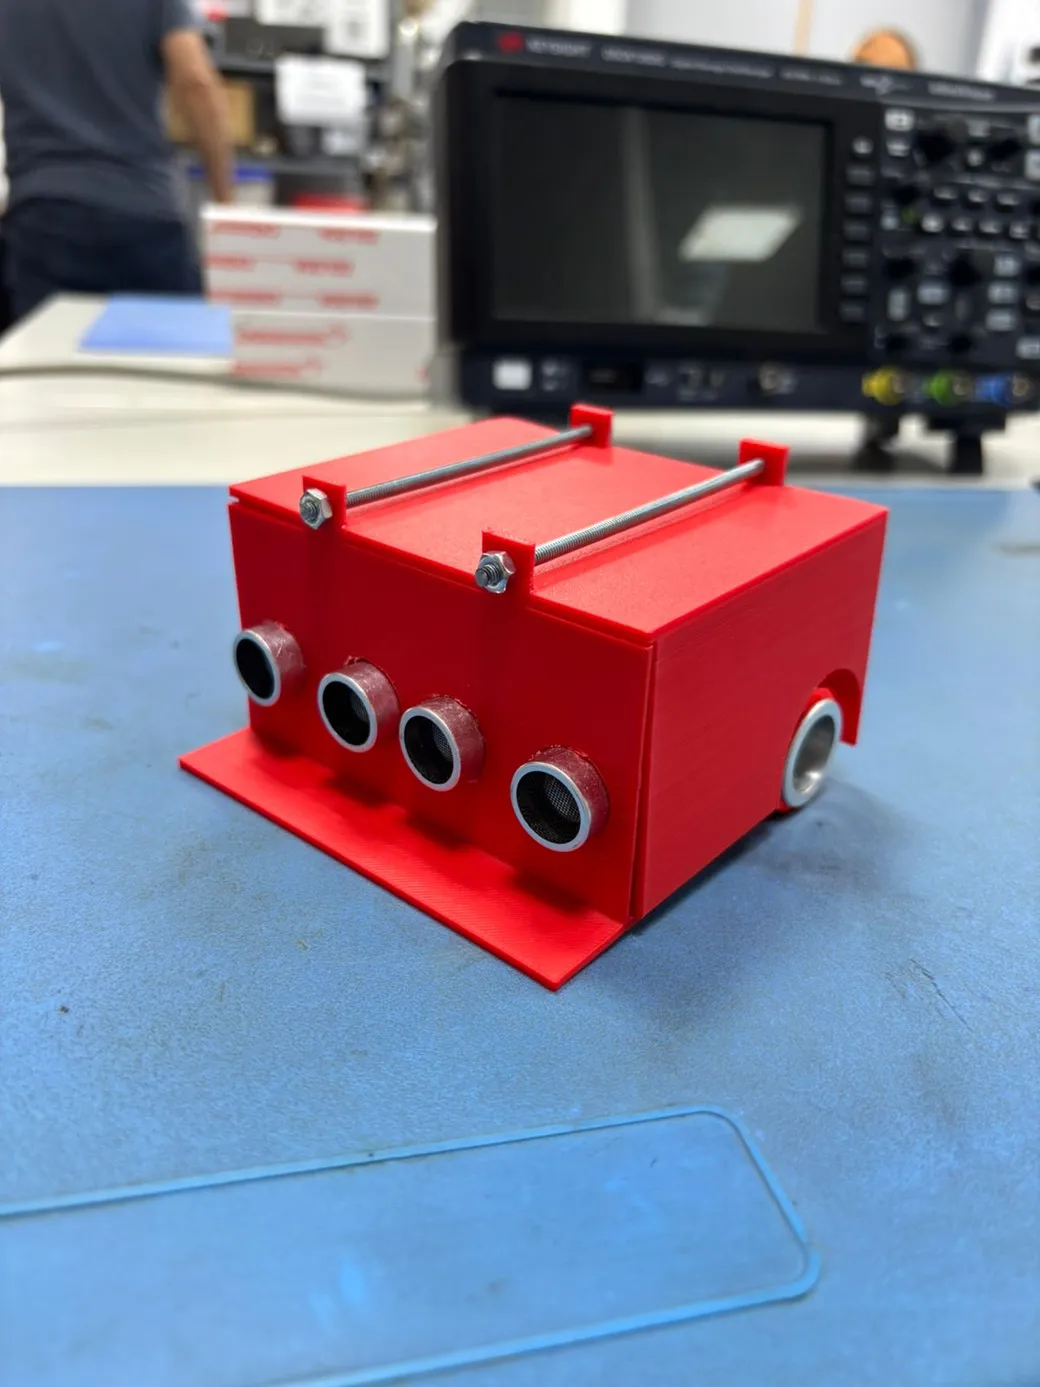
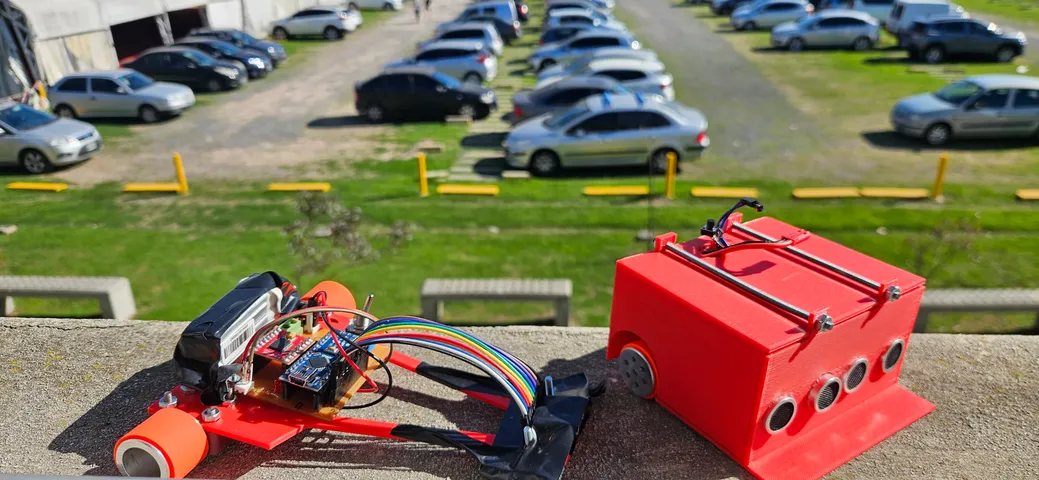
The revision improved the casing and electronics, added a second ultrasonic sensor for wider coverage, and gave the robot memory of the last direction the enemy was seen - so it turns toward the opponent instead of resuming a blind search.
What I’d change next time
The front plate should be a lot sharper. A steel blade could be used to make it more competitive on a face to face situation. Also, an easier on/off switch system should be incorporated and planned from the start to work with the casing. Either ultrasonic or long range infrared sensor should be added to each side of the robot in order to have a much better sense of the environment.
Video & photos