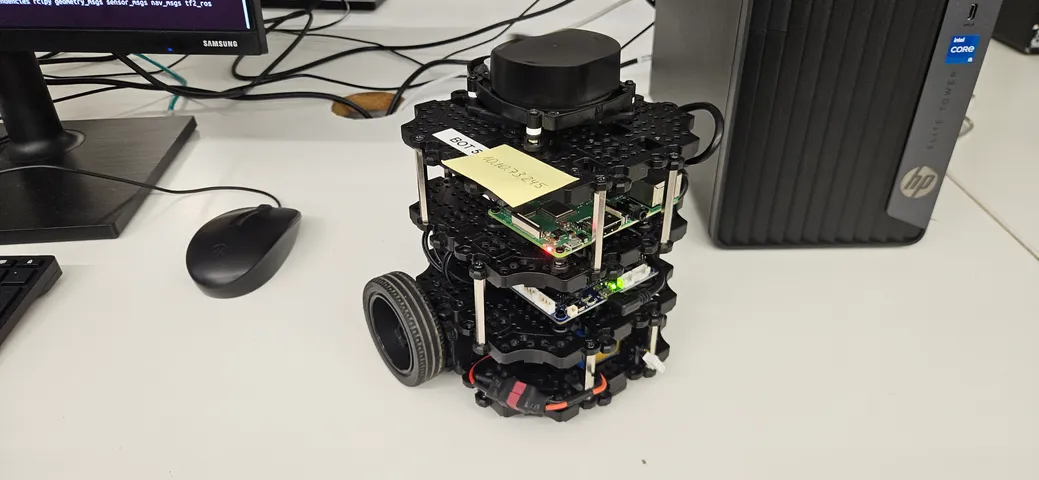
Modelo provisorio · arrastrá para rotarArrastrá para rotar · hacé clic en una pieza para aislarla
Bitácora
Navigation logic
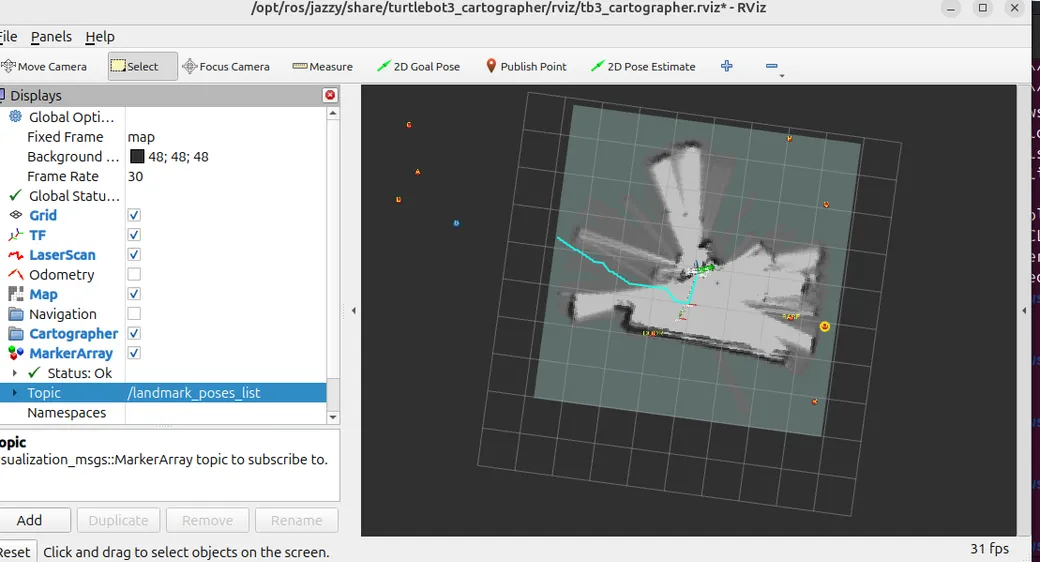
We decided to use the A* path planning algorithm to tackle the waypoint navigation task, while for specific obstacles found in the way, we implemented a pivot point algorithm, in which when faced with an impediment while following the planned path, the algorithm looked for free points on the same horizontal line as the obstacle. If found, it was loaded as a new waypoint and A* replanned with it in mind, successfully avoiding the obstacle and resuming the path to the objective.
Wiring the ROS 2 graph
Todavía sin escribir.
What I’d change next time
Todavía sin escribir.
Video y fotos